Digital Twin & Simulation
Overview
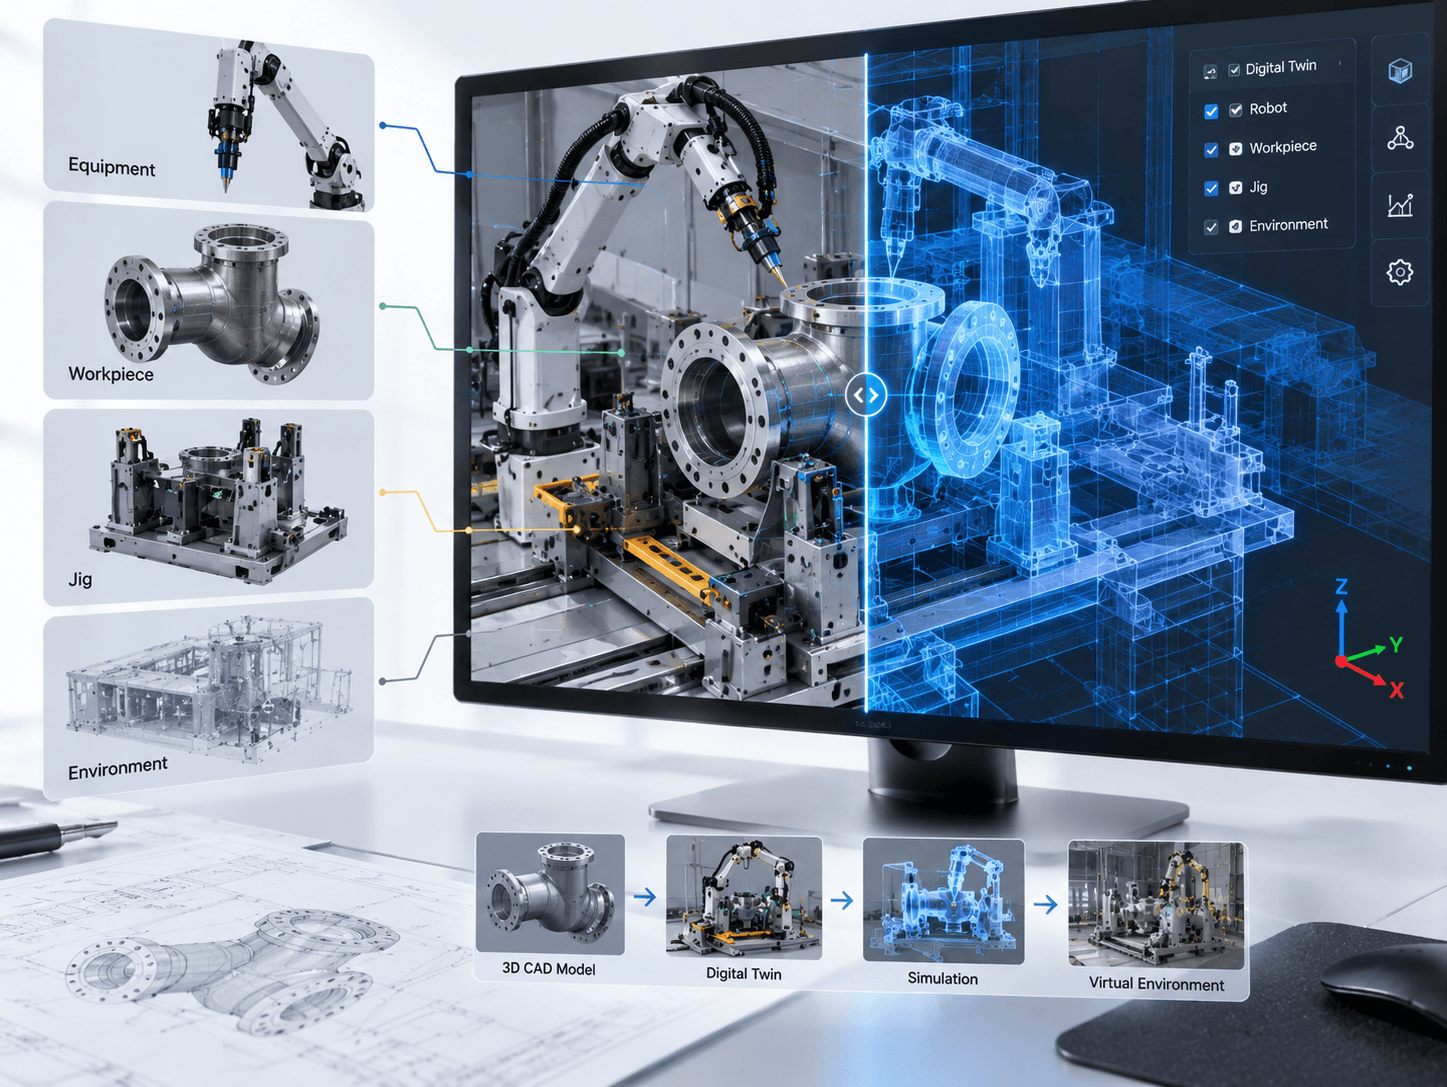
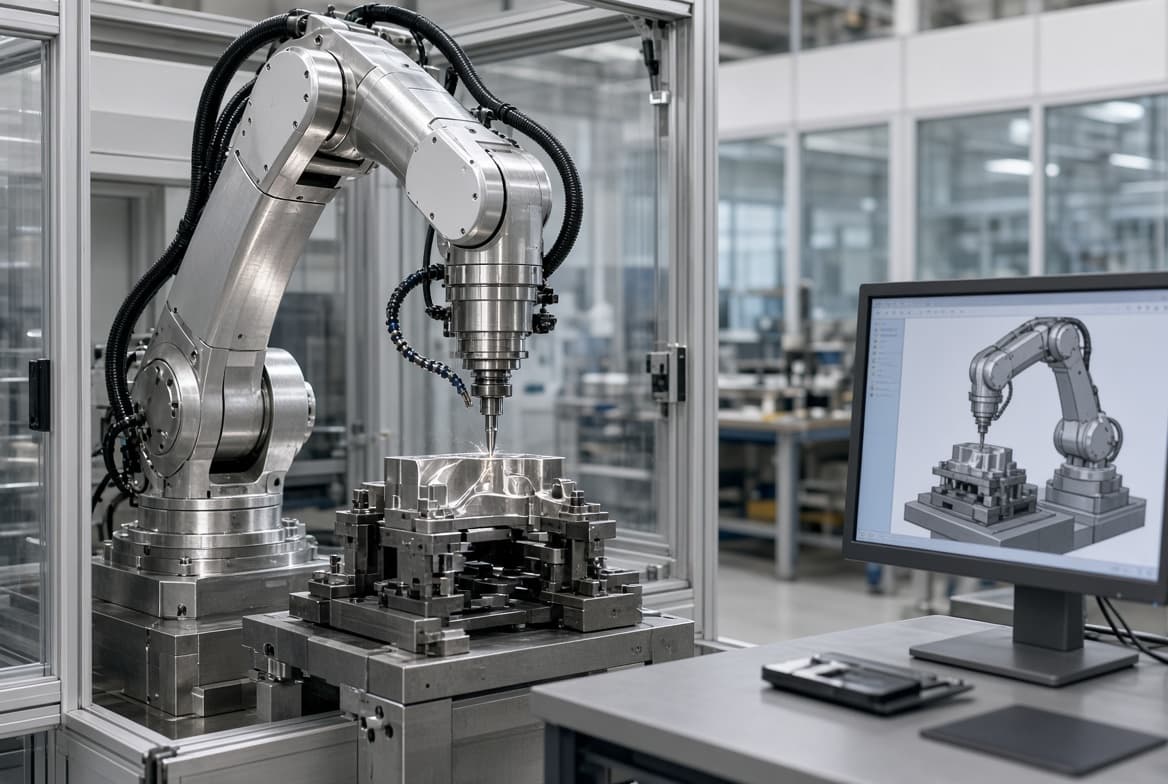
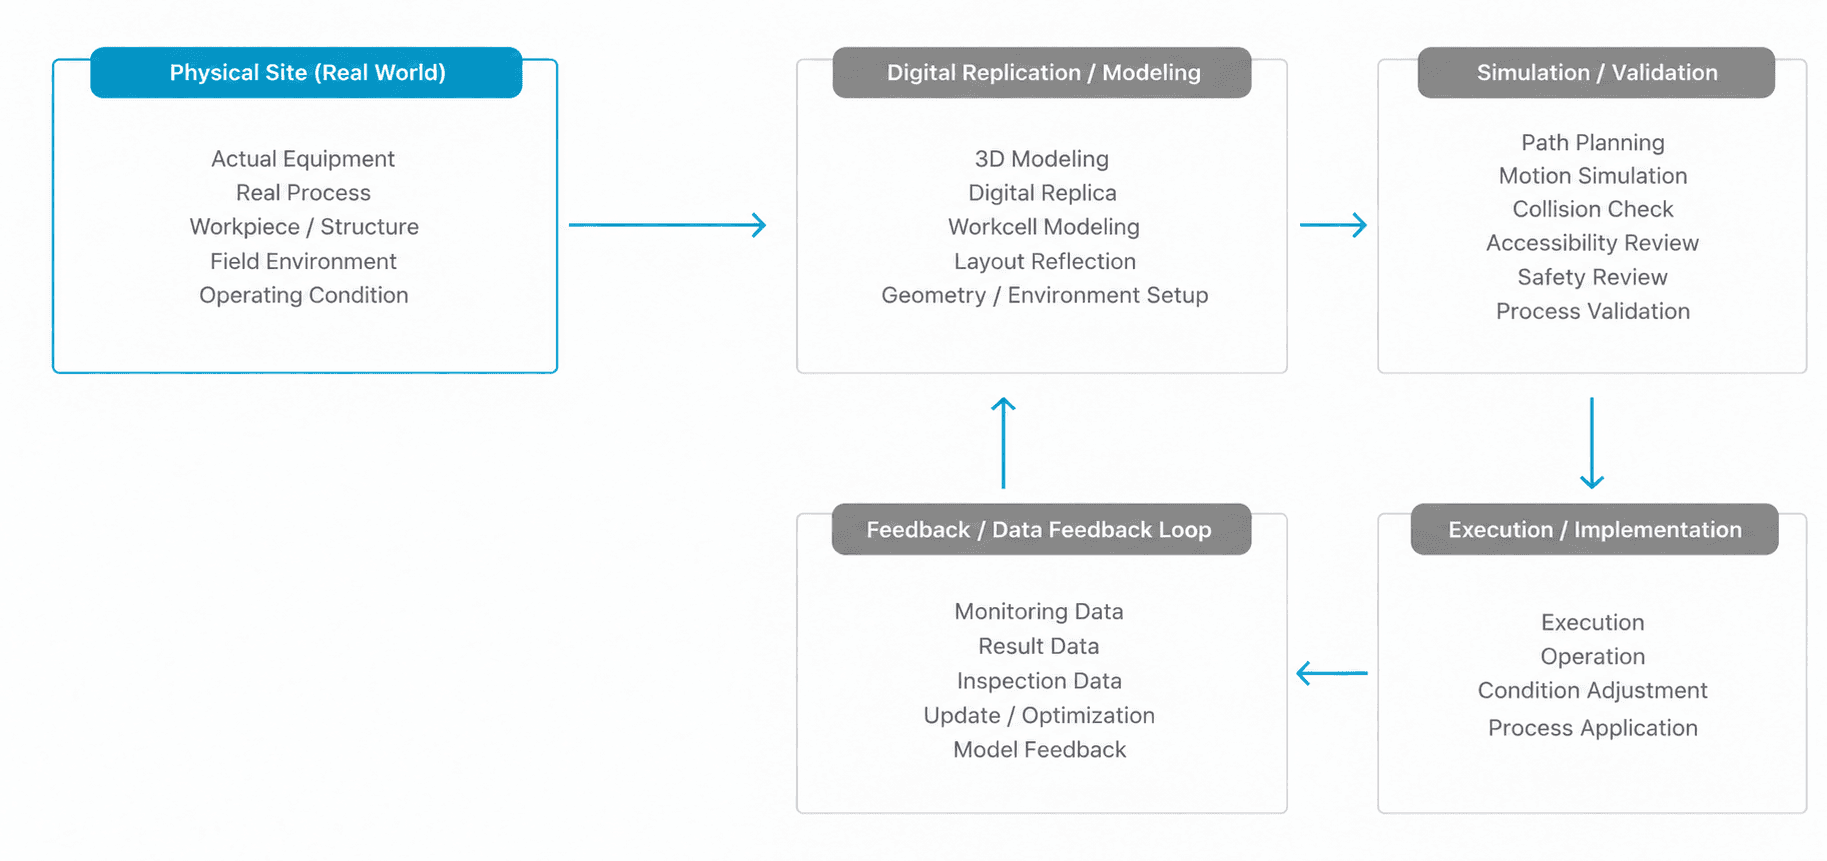
MUTRON builds digital representations of equipment and working environments, connecting design, control, and process data to validate equipment and processes before deployment. Robots, workpieces, jigs, tools, and surrounding equipment are modeled together in 3D. We check working areas, access, robot poses, work paths, and potential collisions and interference before equipment is deployed. CAD models, robot control information, and sensor and process data connect the virtual environment with physical equipment, supporting engineering from design through commissioning and field operation.
What Makes Us Different
MUTRON's digital twin is a virtual validation technology that goes beyond simple 3D visualization to support actual equipment design and process decisions. We precisely analyze work paths and orientations based on the coordinate relationships among the robot, workpiece, and tool/tool center point (TCP). We validate equipment layout, work sequences, tool accessibility, and interference with surrounding structures in advance. In particular, we apply digital pre-validation to processes where site access is restricted and highly reliable work is required. Examples include nuclear power plant MRO, as well as welding and machining. This approach reduces the burden of on-site setup and the amount of trial and error. We also incorporate control, sensor, and process data collected from actual equipment into the digital environment. In this way, we establish a framework for continuous process advancement that connects design, validation, and operation.
CORE TECHNOLOGIES
MUTRON precisely replicates actual equipment, workpieces, jigs, and surrounding environments in a CAD-based 3D space.